SENSORAMA
Multimodal XR — EU project, coordinated by the University of Bremen
Multisensory extended reality: combining visual, auditory and haptic channels into coherent immersive experiences. Rene contributes to the project coordination and the requirements definition (WP1).
XRHapticsEU
VaMEx — Valles Marineris Explorer
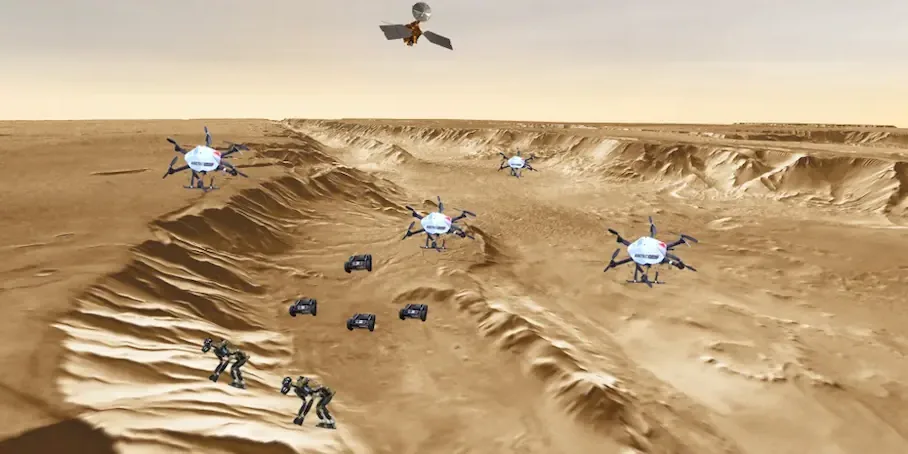
Heterogeneous robot swarms for Mars exploration (DLR) — overall coordinator of the initiative
A swarm of rovers, hoppers and drones autonomously exploring the Valles Marineris. I coordinate the initiative as a whole across its partner institutions; CGVR builds the virtual testbed (VaMEx-VTB) for validating swarm navigation before any hardware exists, and VR interfaces for planning exploration missions.
SpaceSimulationSwarm robotics
Project portalVaMEx-VTB at CGVR
UnrealHaptics
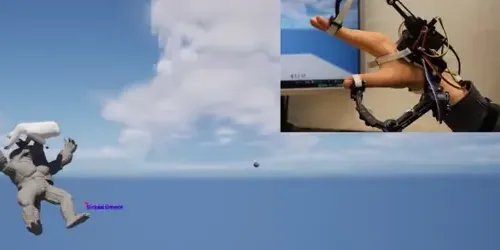
Haptic rendering inside modern game engines
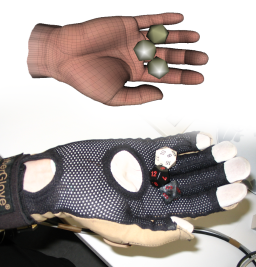
A plugin system that brings 1 kHz haptic loops, grasping and — most recently — multi-contact devices (UnrealHaptics-MC, Eurohaptics 2026) to Unreal Engine 5. Open source.
HapticsUnreal EngineOpen source
Project page
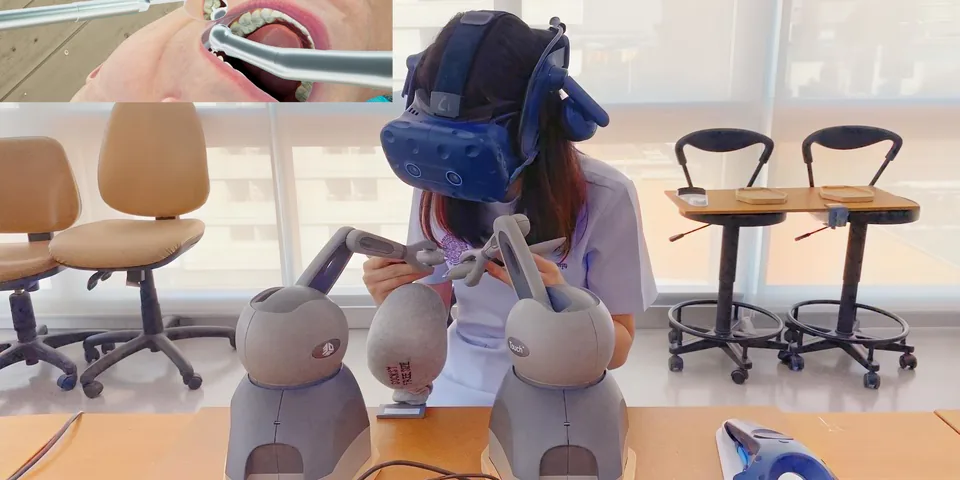
Dental & surgical VR training
With Thammasat University and Mahidol University, Thailand
Haptic VR simulators for endodontics and indirect-vision dentistry, evaluated in randomized controlled trials; plus HIPS, a hip arthroplasty simulator with realistic bone-milling force feedback.
Medical VRHaptics
Dental simulatorHIPS
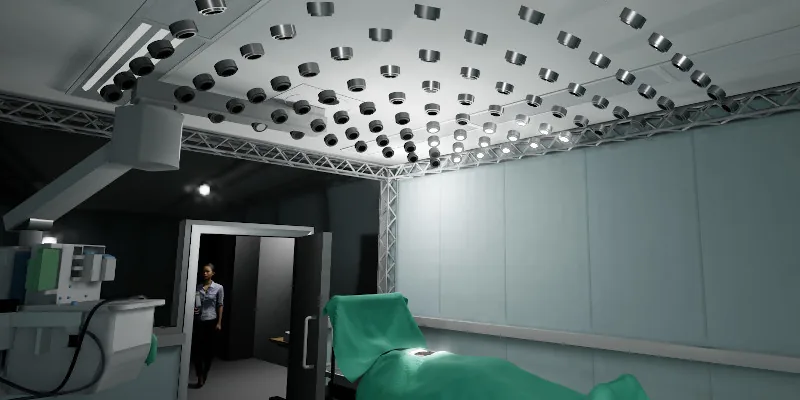
Smart operating theatre
SmartOT / autonomous surgical lamps / shadow-free projection
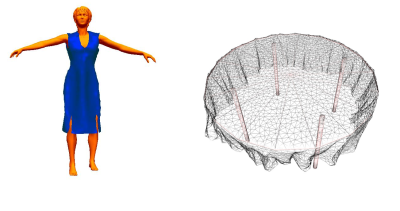
Autonomous, module-based surgical lighting that keeps the wound illuminated without manual repositioning, and projection mapping onto dynamic, deformable surfaces without shadows.
Medical VROptimization
SmartOT
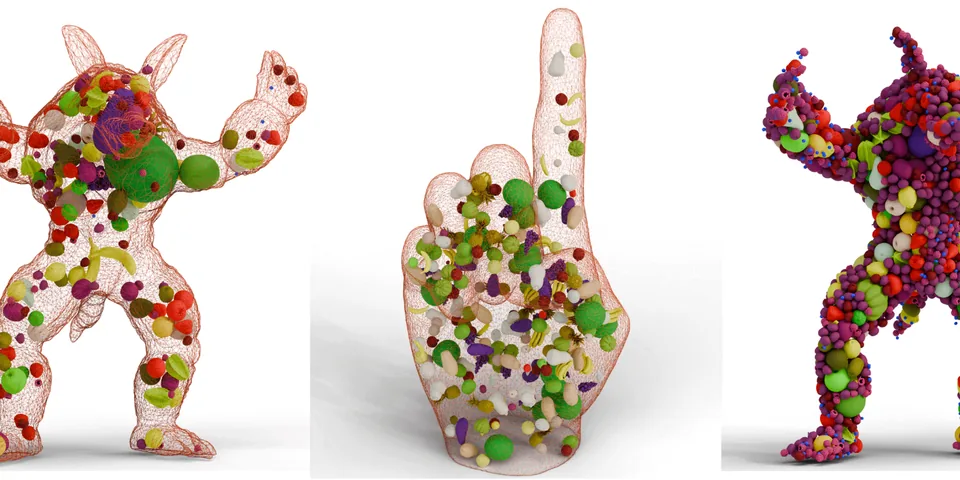
3D Packing & sphere packings
Multi-objective packing of arbitrary objects into arbitrary containers
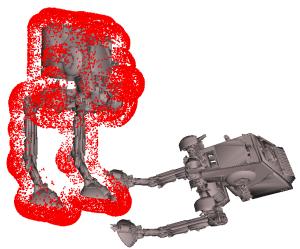
Sphere-packing based algorithms for dense placement of 3D objects, with applications from logistics to gravitational field modelling of asteroids.
GeometryOptimization
3D Packing
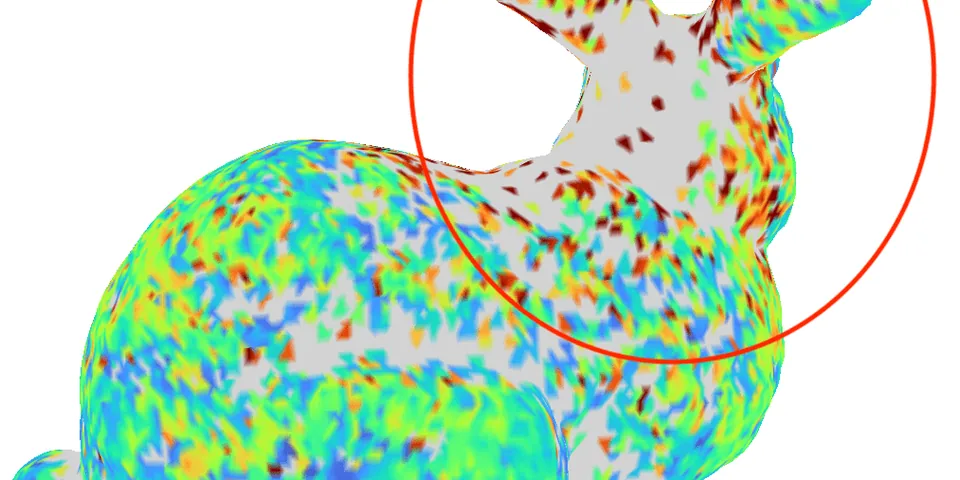
OpenCollBench
Web-based benchmarking of collision detection libraries
The successor of our original benchmarking suite: upload your algorithm, run standardized scenarios on our servers and compare.
Collision detectionBenchmark
OpenCollBench